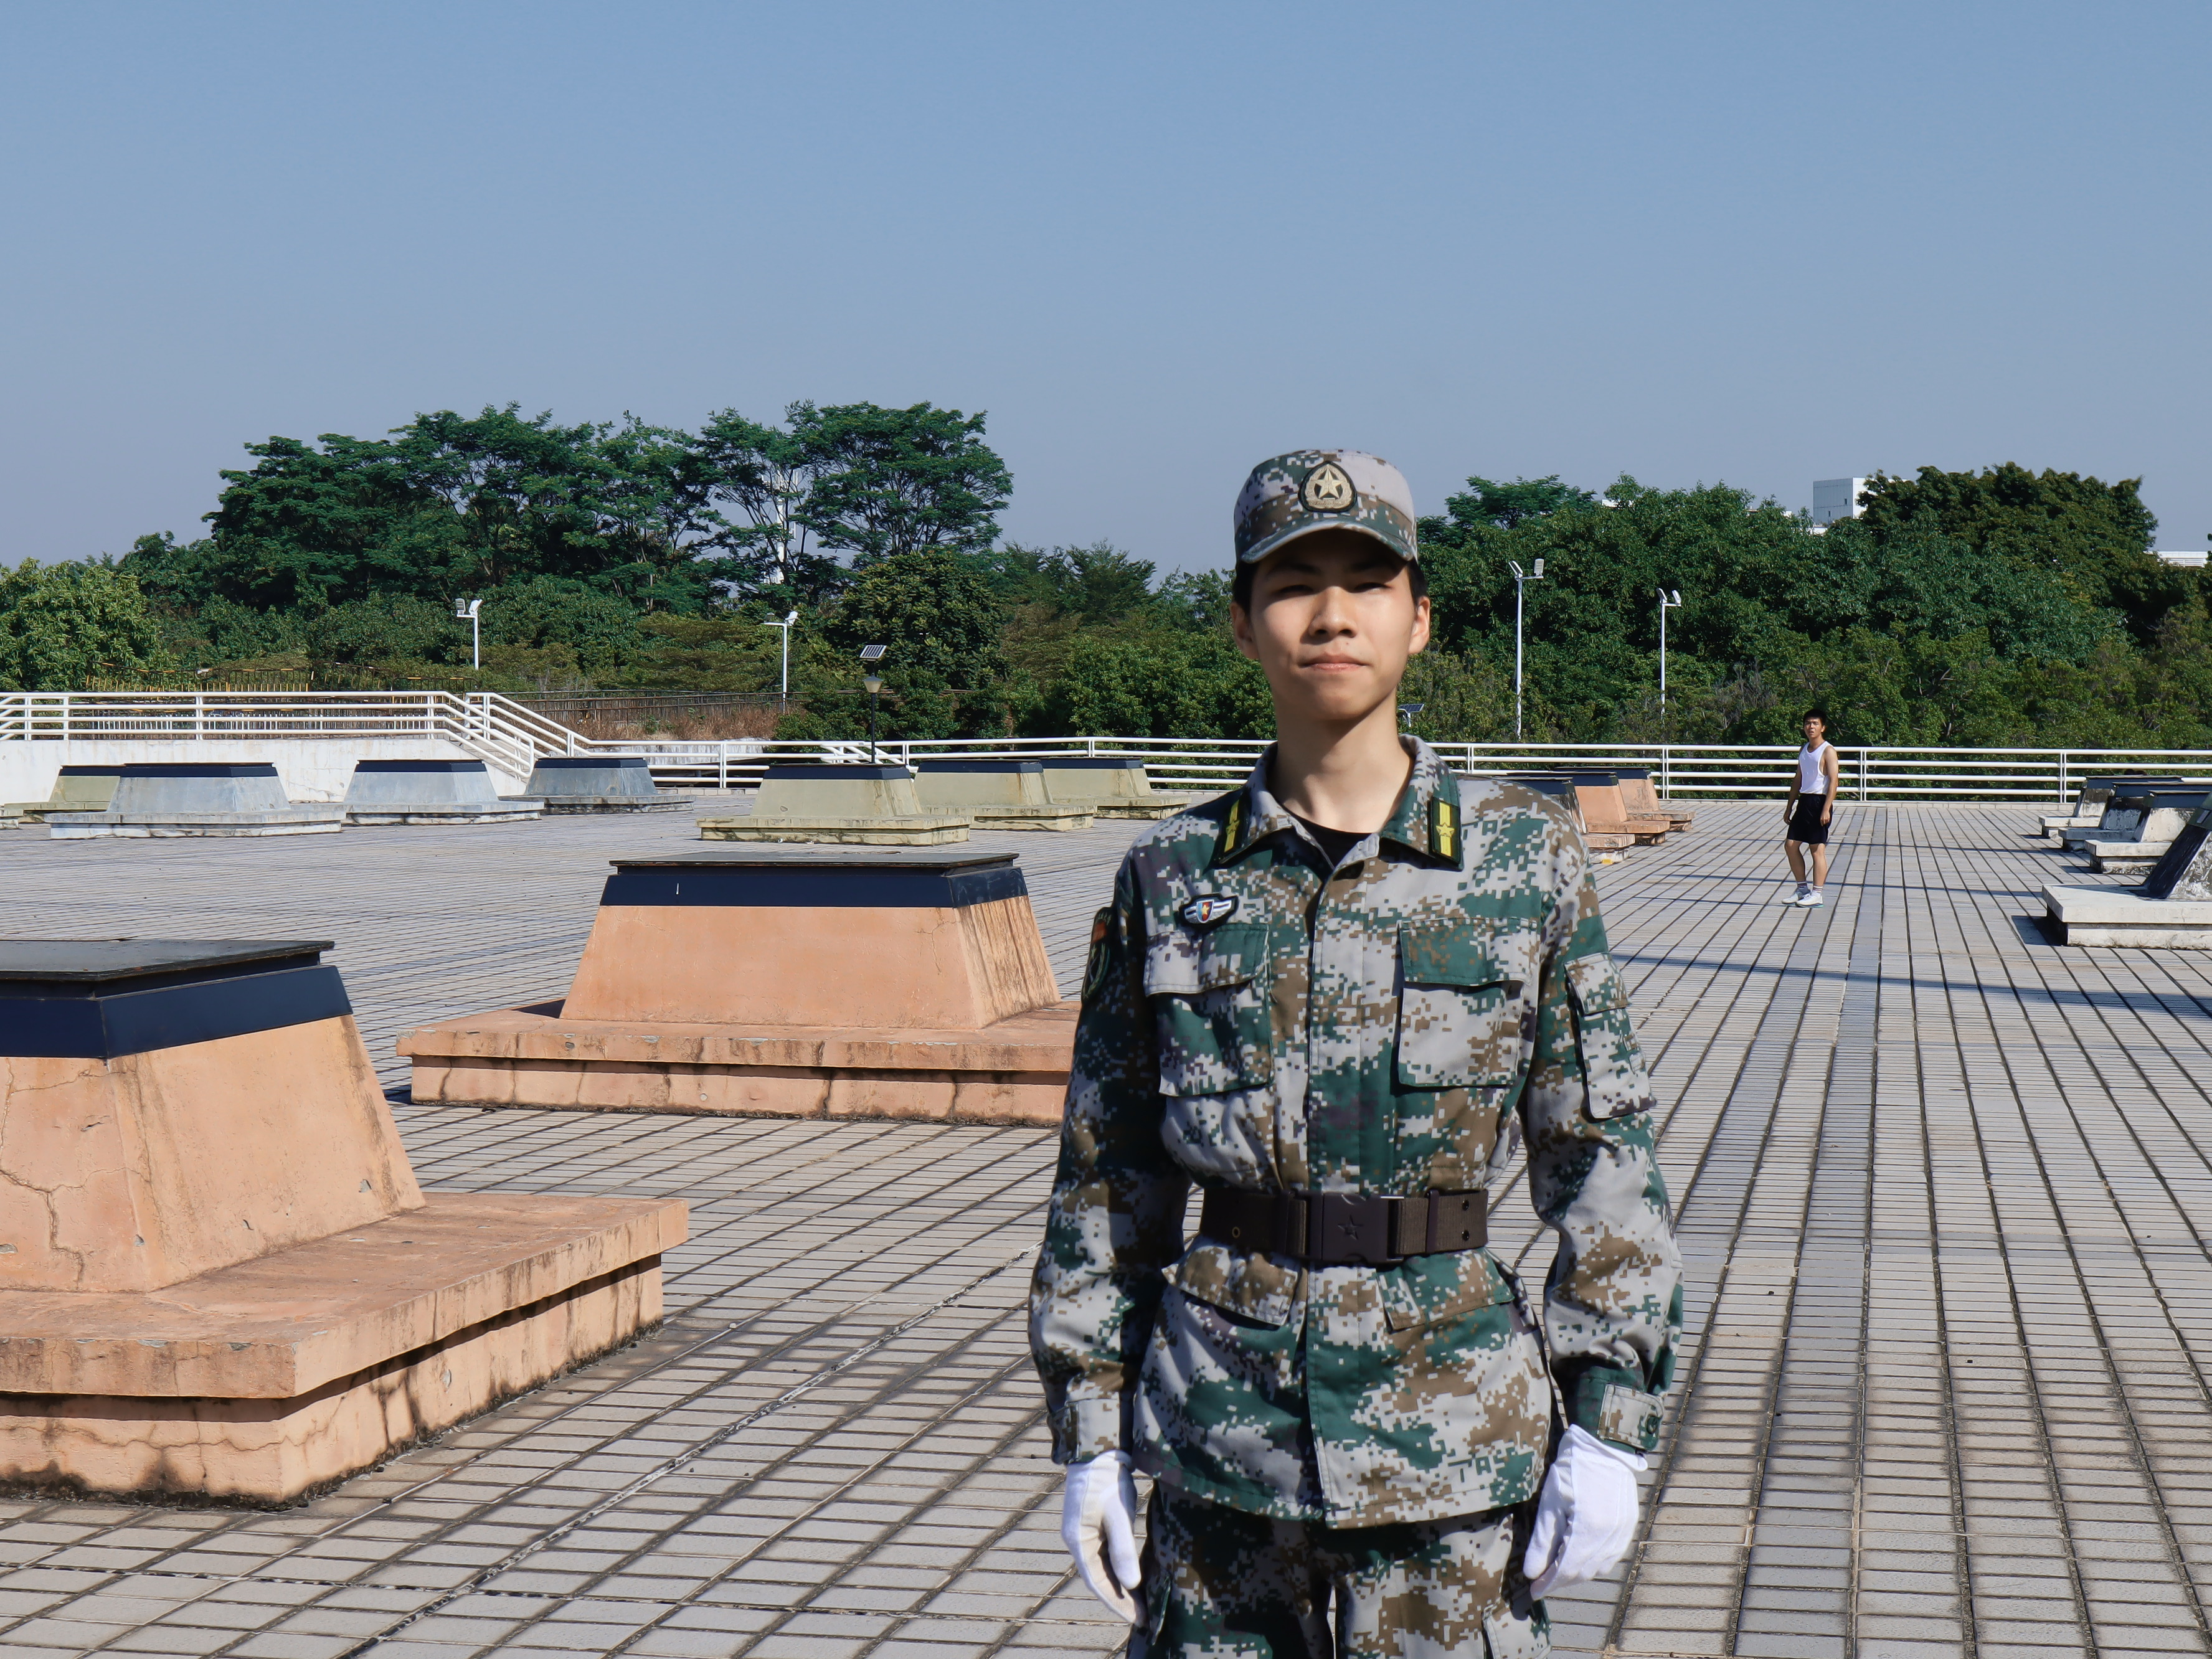
何健聪Jiancong He
广东工业大学 · 自动化 · 创新班 GDUT · Automation · Innovation Class
本科就读于广东工业大学自动化学院自动化专业(国家第四轮学科评估 A 类)创新班。 GPA 4.130,排名 14/357(Top 4%)。CET-4 530,CET-6 514。 核心课程:现代控制理论(95)、信号与系统(93)、电气控制技术与 PLC(93)、机器人学(91)。 师从常乐老师,加入ECS Lab课题组,主持大创项目《基于博弈论的无人机空地协同路径规划研究》。 数学建模省二等奖、统计建模省三等奖、蓝桥杯 Python 组省三等奖两次、校优秀学生二等奖学金两次(Top 6%)。爱好摄影与运动。
Undergraduate in Automation (National A-Class Discipline) at GDUT Innovation Class. GPA 4.130, Rank 14/357 (Top 4%). CET-4 530, CET-6 514. Core courses: Modern Control Theory (95), Signals & Systems (93), PLC Technology (93), Robotics (91). Joined ECS Lab under Prof. Chang Le, led the university research project on game-theoretic UAV air-ground cooperative path planning. Awards include Mathematical Modeling (Provincial 2nd), Statistical Modeling (Provincial 3rd), Lanqiao Cup Python (Provincial 3rd ×2), GDUT Second-Class Scholarship (Top 6%) ×2. Hobbies: photography, sports.
-
提出以公交车为载体的边缘服务器方案,设计基于贪婪算法的公交车选择策略,在预算限制下最大化用户覆盖率。
Proposed bus-mounted edge server deployment with a greedy bus selection algorithm to maximize user coverage under budget constraints.
-
无人机空地协同路径规划UAV Air-Ground Cooperative Path Planning
梳理斯坦伯格博弈与多智能体强化学习(MADDPG、MAPPO)理论。YOLO 部署至 Tello 摄像头,实现目标识别与短距位移。
Systematic study of Stackelberg game and MARL (MADDPG, MAPPO). Deployed YOLO on Tello UAV for object detection and short-range navigation.
-
ABB 机械臂电池装配产线ABB IRB 120 Battery Assembly Line
Portal v16 组态 S7-1500 PLC,Profinet 控制 V90/G120 伺服与无刷电机。RobotStudio 编程并示教。PLC I/O + HMI 实时反馈。扩展控制 Baxter 双臂机器人,手部视觉颜色抓取。
Configured S7-1500 PLC via Portal v16. Profinet control of V90/G120 servos. RobotStudio programming. Extended to Baxter dual-arm robot with hand-eye color grasping.
-
个人网站 & 内网穿透Personal Site & Tunneling
自主搭建,Cloudflare Tunnel 穿透内网,外网访问本地服务。Cloudflare Pages 托管,支持中英双语、深浅色模式。
Self-built with Cloudflare Tunnel for remote access. Cloudflare Pages hosting, bilingual, dark/light mode.
-
国旗护卫队National Flag Guard
2023.09–2024.06 队员 · 2024.09–2025.06 作训部副部长
2023.09–2024.06 Member · 2024.09–2025.06 Deputy Training Officer
-
新生学长Freshman Mentor
2024.09–2025.06
2024.09–2025.06
-
班长Class President
2025.03–至今
2025.03–Present
-
党支部副书记Deputy Branch Secretary
2026.06–至今
2026.06–Present